
Quadcopter Dynamics & PID Control | 3D Drone Trajectory Tracking in MATLAB
$9
3 Personen haben dies gekauft
📌 Product Overview
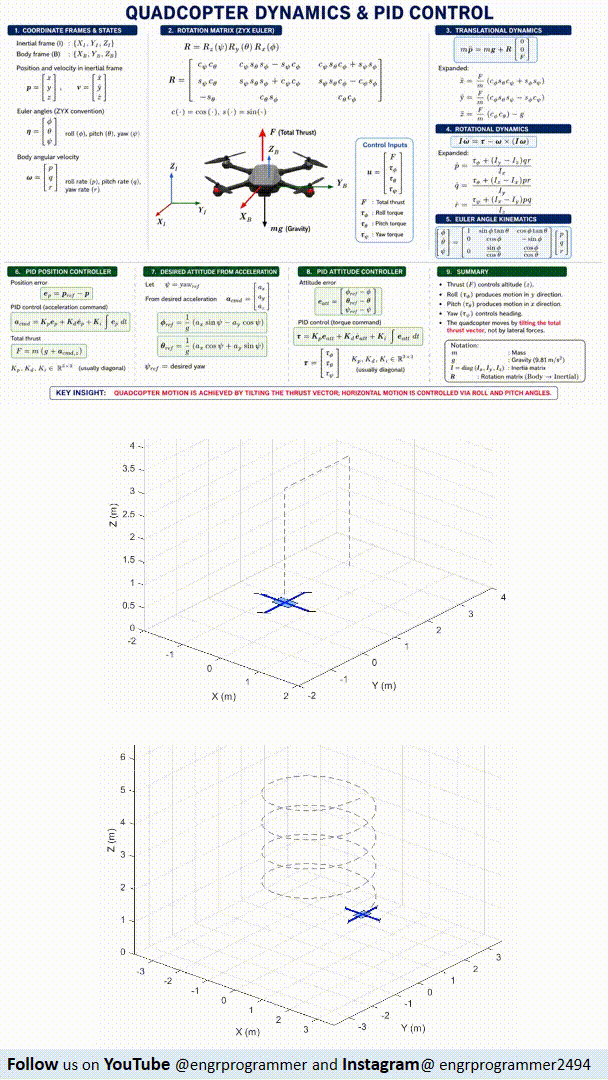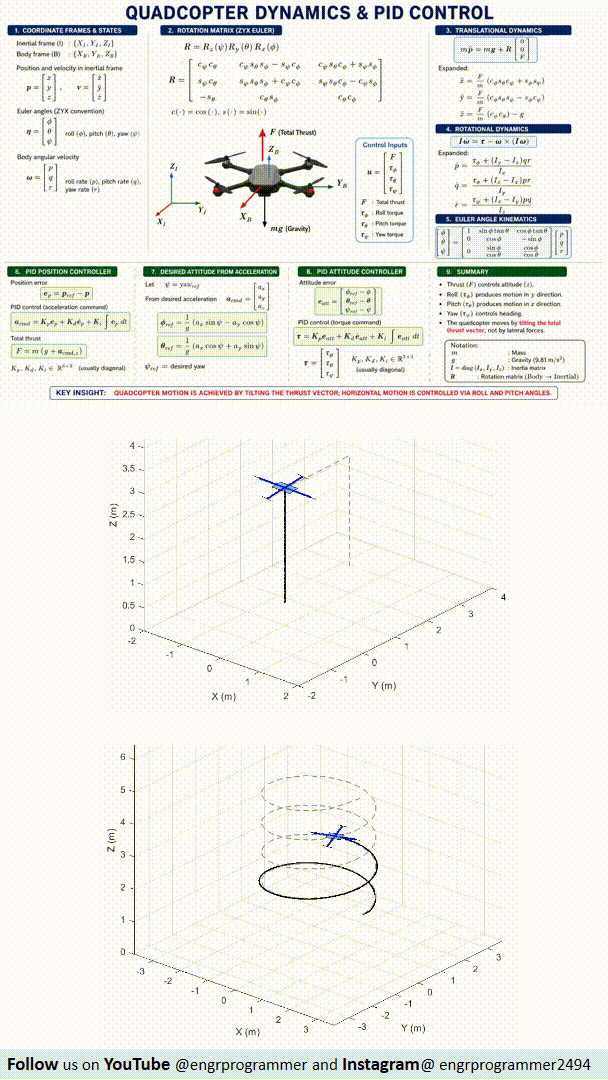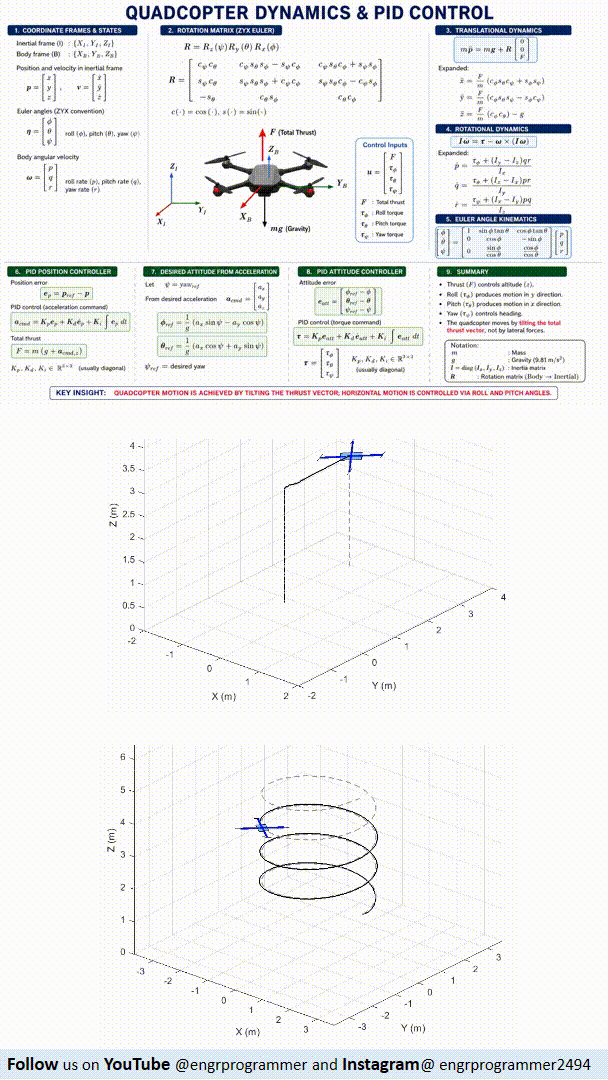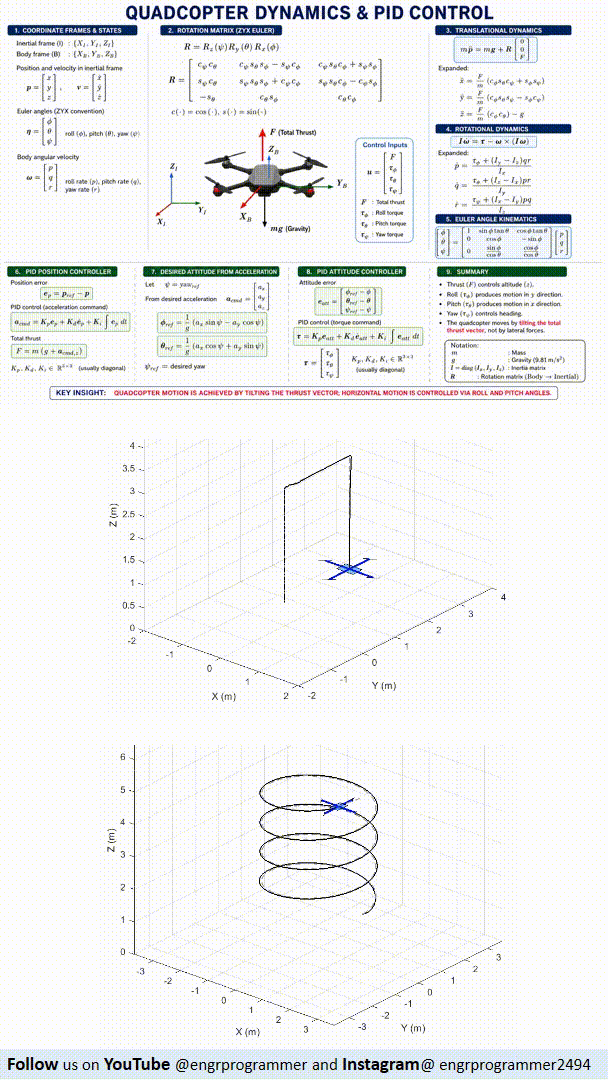
This is a complete engineering-grade MATLAB simulation of a quadcopter using a Cascaded PID control system for stable flight and trajectory tracking in 3D space.
Designed for students, researchers, and robotics enthusiasts, this project bridges the gap between control theory and real-world UAV behavior through realistic dynamics and visualization.
⚙️ What You Will Get
✔️ Full Quadcopter Nonlinear Dynamics (6-DOF Model)
✔️ Cascaded PID Controller (Position + Attitude Control)
✔️ Real-Time 3D Animation (Smooth Visualization)
✔️ Multiple Trajectory Generators:
Circle
Figure-8
Helix
Custom Path
✔️ Clean, Well-Structured MATLAB Code
✔️ Automatic Simulation Video Export (MP4)
✔️ Ready-to-Run Project (No setup complexity)
📊 Key Features
Stable hover control
Accurate trajectory tracking
Physics-based realistic motion
Tunable PID parameters
Publication-style visualization
Smooth rotor animation & trail tracking
🎯 Ideal For
✔️ Final Year Engineering Projects (FYP)
✔️ Robotics & Mechatronics Students
✔️ Control Systems Courses
✔️ MATLAB Simulation Learning
✔️ Academic Research & Demos
💡 Why This Project?
Most tutorials show only equations —
this project shows real motion behavior of a quadcopter in 3D space 🚁
You don’t just learn PID…
you see how it controls a flying system in real time.
📁 File Format
MATLAB .m files
Ready-to-run simulation
No external toolboxes required (basic MATLAB only)
🚀 How to Use
Download the project
Open MATLAB
Run main simulation file
Select trajectory
Watch real-time flight + save video
📈 Learning Outcomes
After using this project, you will understand:
How quadcopter dynamics are modeled
How PID controls nonlinear systems
How cascaded control architecture works
How trajectory tracking is implemented in UAVs
📩 Support
Need help or customization?
Feel free to contact on instagram @engrprogrammer2494 or email [email protected]
$9
3 Personen haben dies gekauft
Gib einen fairen Preis ein
$
$9