
joints positions editor.ttm , CoppeliaSim model
€5
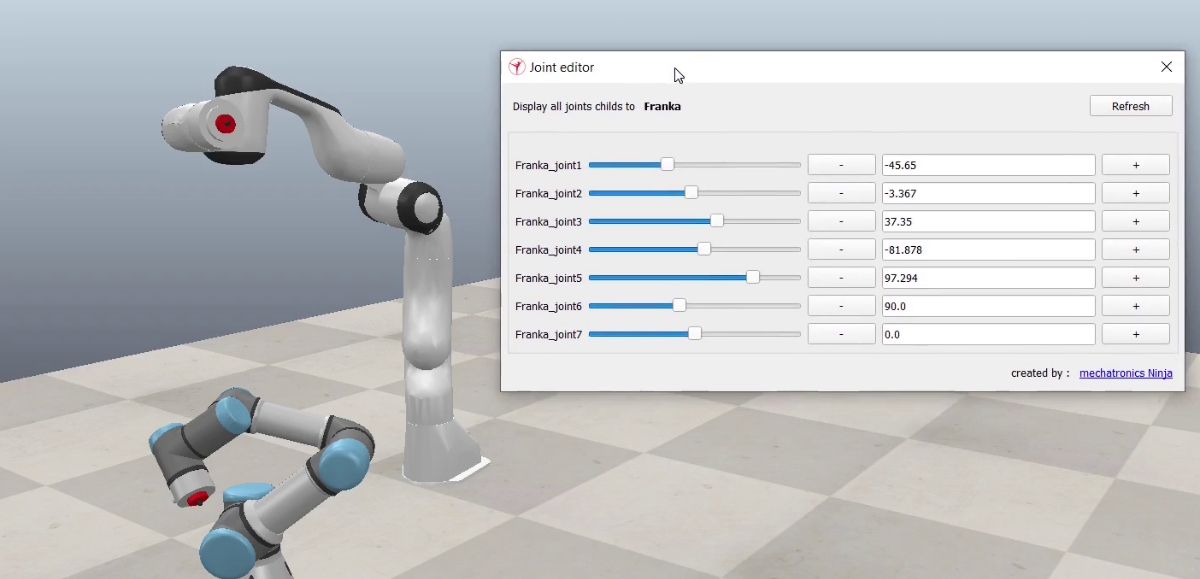
This model will facilitate the axis jogging of your robot. Place this model dummy as a child on the robot base that you want to display its joints. All the joints will be displayed and you can easily edit their positions
Please note that the spherical joints are not displayed.
It is working with the 4.2 and 4.3 versions of CoppeliaSim.
The below video demonstrates how its works (at 3:30)
https://www.youtube.com/watch?v=1u0_0wfUhl0&ab_channel=mechatronicsNinja
Please note that the spherical joints are not displayed.
It is working with the 4.2 and 4.3 versions of CoppeliaSim.
The below video demonstrates how its works (at 3:30)
https://www.youtube.com/watch?v=1u0_0wfUhl0&ab_channel=mechatronicsNinja
€5
Gib einen fairen Preis ein
€
€5