
Engr ProgrammerBoutiqueSystem Dynamics and Multibody Modeling: From First Principles to 3D Simulation in MATLAB Simscape Multibody (PDF)
System Dynamics and Multibody Modeling: From First Principles to 3D Simulation in MATLAB Simscape Multibody (PDF)
$35
Abstract
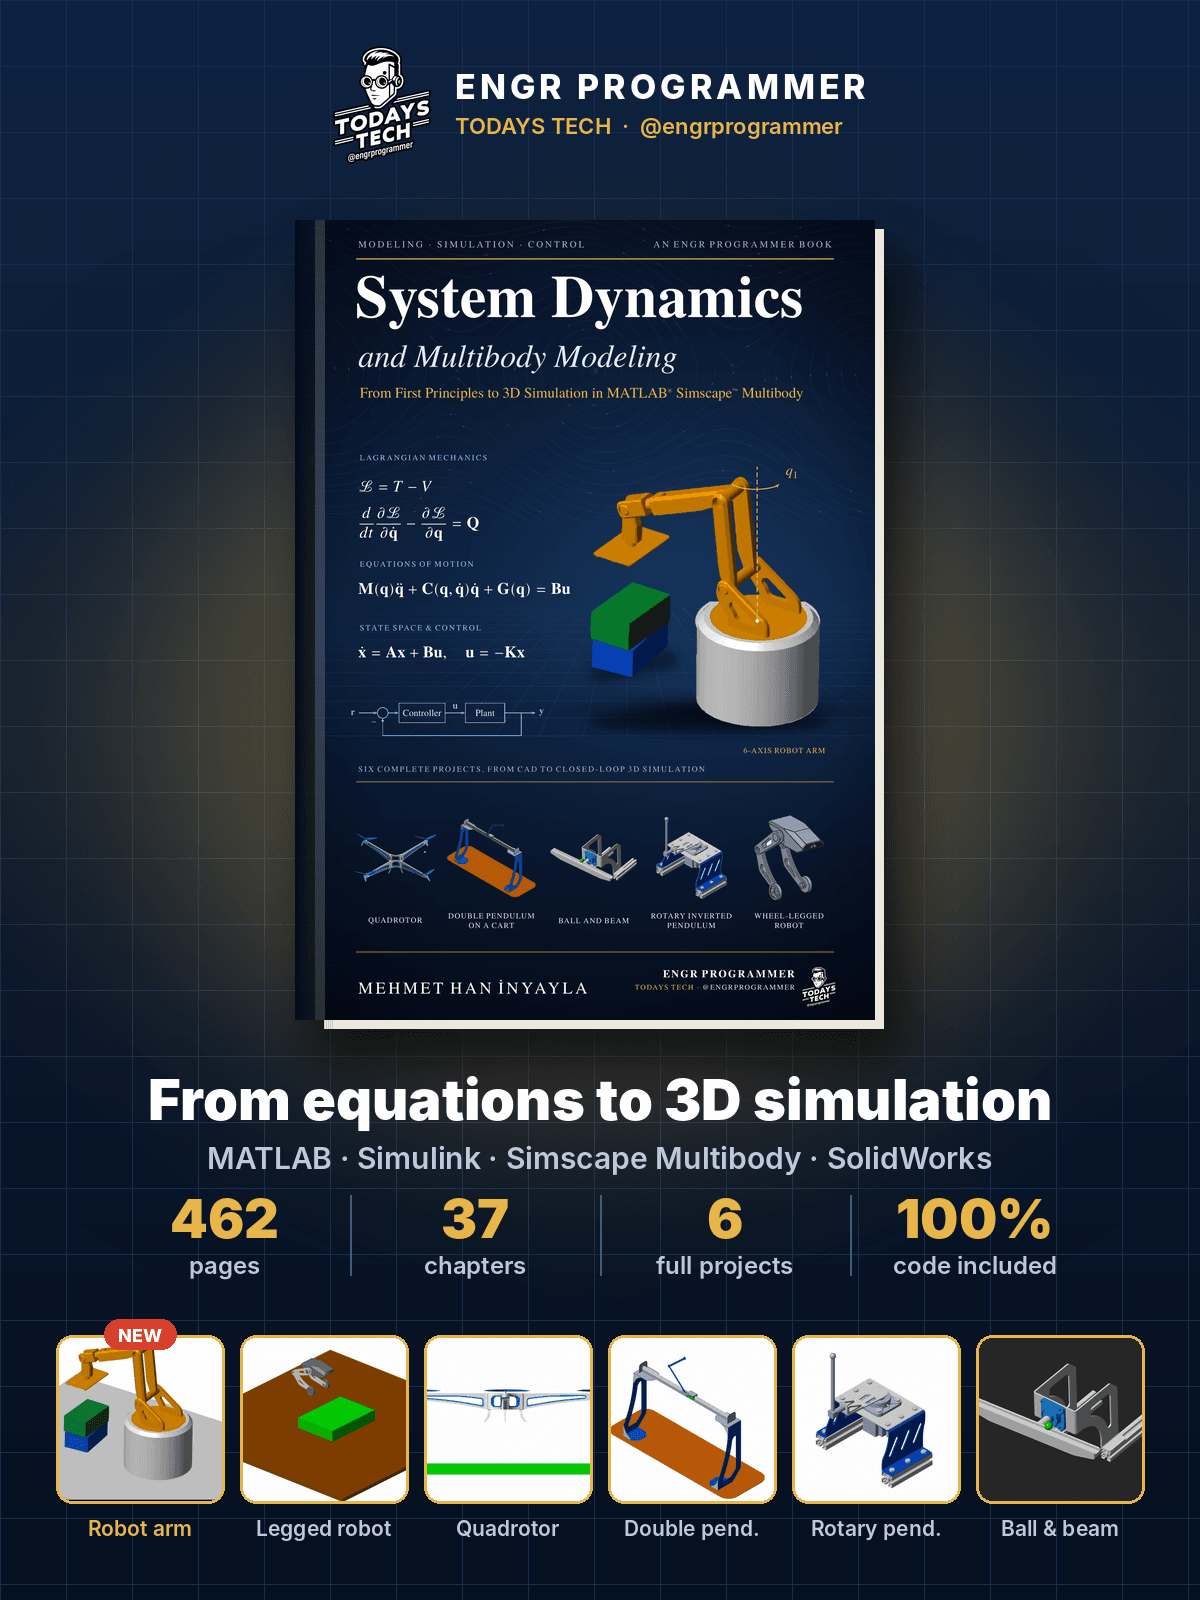
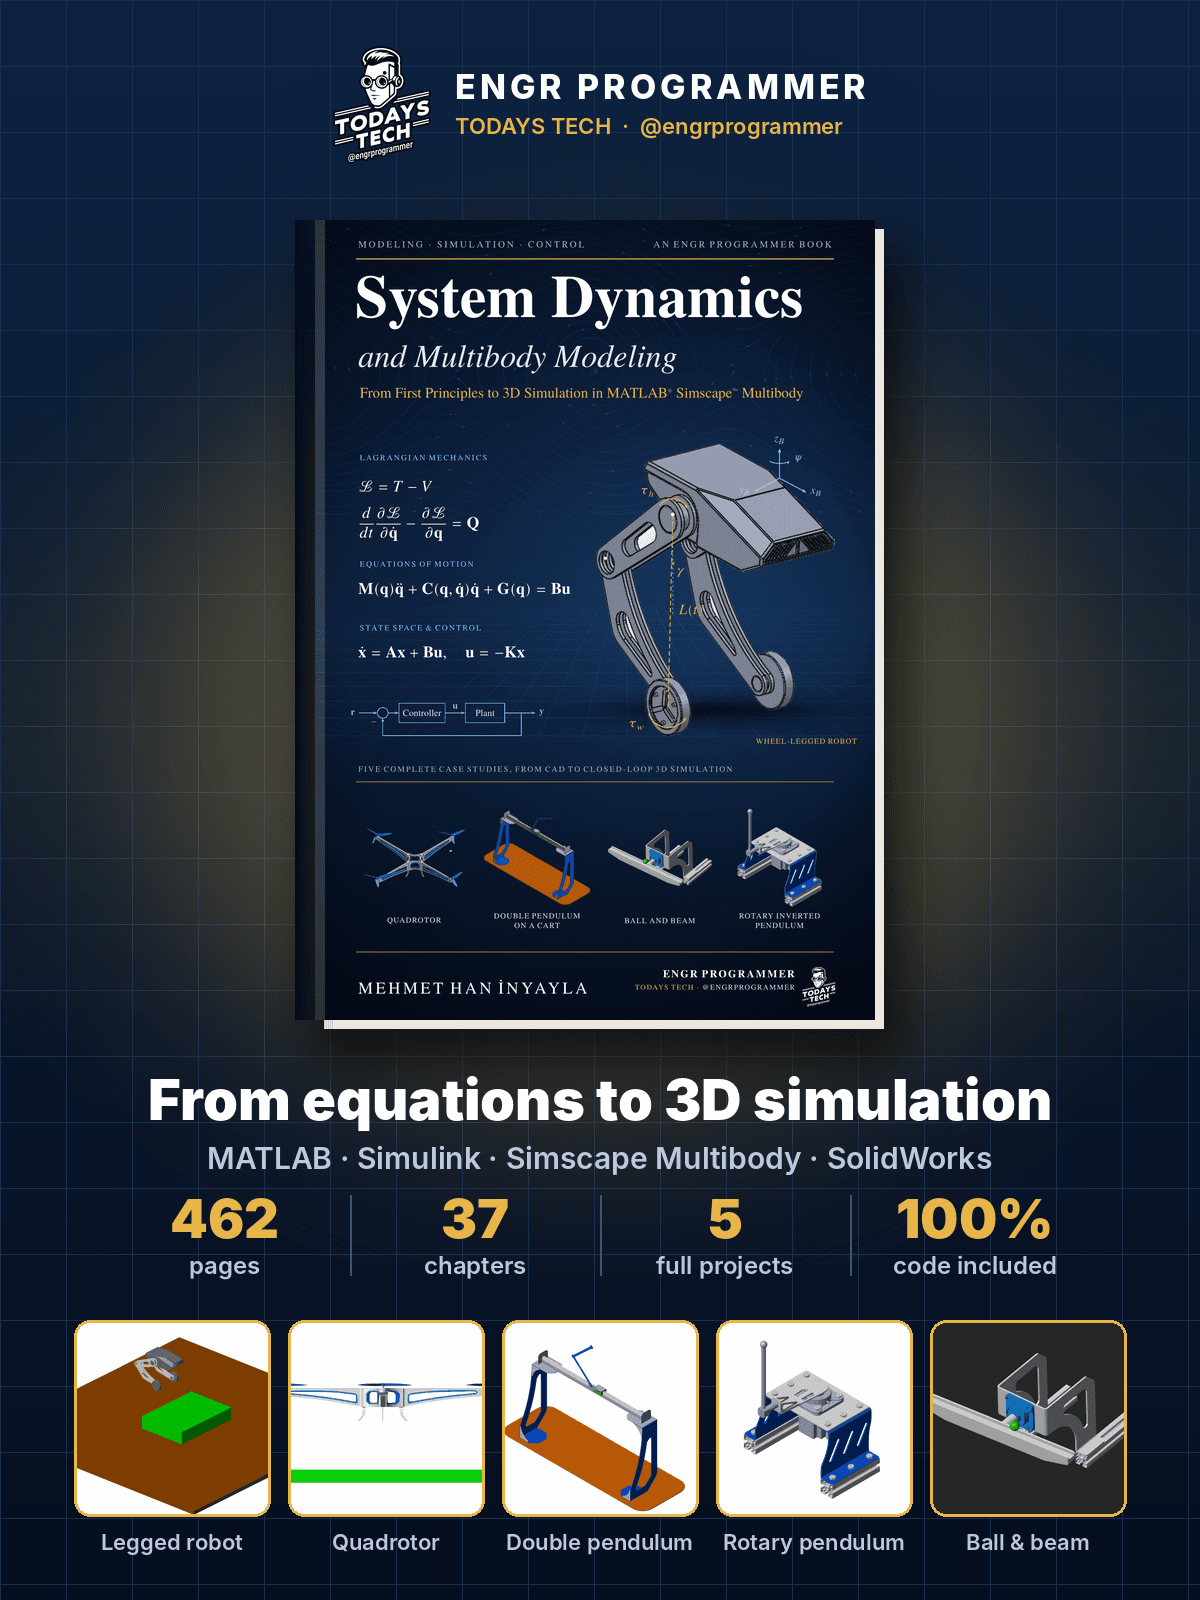
A 462-page textbook that takes you from differential equations to full 3D robot simulations in MATLAB Simscape Multibody. It walks through five real projects step by step, with complete code, and now includes a free bonus project: a 6-axis robot arm that picks up and stacks boxes with a vacuum gripper.
Full description
Watch a wheel-legged robot jump onto a box, a double pendulum swing up and balance, a drone fly a full mission, and a 6-axis robot arm pick up two boxes and stack them. All of it happens in simulation before any hardware is built. This book shows you exactly how each one was made.
System Dynamics and Multibody Modeling builds the theory first, then puts it to work. You start from first principles, derive the mathematical model of each system, and then build and control it in MATLAB Simscape Multibody, from SolidWorks CAD to closed-loop 3D simulation.
What you’ll learn
- Mathematical foundations. Differential equations and their solutions, the Laplace transform, root locus, state space and vibration.
- Mechanics. Newton–Euler, Lagrange and Hamilton methods, compared side by side on the same examples.
- Control. PID, LQR, energy-based swing-up, optimal control, digital control and state estimation, with direct comparisons.
- Simulation. Numerical integration, friction, contact and impact.
- MATLAB and Simscape Multibody. Importing SolidWorks assemblies, building models by script and by hand, adding sensors, actuators and motors, and running batch simulations.
- Verification and validation. How to prove your simulation is right.
Five complete case studies
- Rotary inverted pendulum: swing-up and LQR balance
- Ball and beam: precision positioning with rolling contact
- Double pendulum on a cart: trajectory optimization and time-varying LQR
- Quadrotor: cascaded control, take-off, manoeuvres and landing
- Wheel-legged robot: balancing, jumping and turning
NEW: Free bonus project, 6-axis robot arm
A 6-DOF robot arm imported from SolidWorks into Simscape Multibody picks up a blue box and a green box with its vacuum suction cups and stacks them precisely. It uses inverse kinematics, smooth joint trajectories, a vacuum gripper model and contact forces with friction. One setup script builds and runs the whole scenario. If you already bought the book, the files have been sent to your email. New buyers get them in the download.
A real design lesson. In the wheel-legged robot, the simulation showed that a flat wheel without a curved (crowned) profile skids and wobbles in turns. The problem was caught before a single part was built.
What’s inside
456 pages, 37 chapters and 8 appendices
Full MATLAB code listings for all five projects
A “Simscape Multibody step by step” appendix that gives the settings for every block in every project
Worked examples, end-of-chapter problems with selected solutions, a glossary and an index
Real-world applications in aerospace, automotive, agriculture and defense
Bonus: complete 6-axis robot arm project files (SolidWorks CAD, Simscape model, MATLAB setup scripts and demo video)
Format: print-ready PDF, English, instant digital download.
Who it’s for: engineering students, mechatronics and robotics enthusiasts, and engineers who want to move from equations to working 3D simulations.
$35
Saisissez un prix raisonnable
$
$35